UPV

Áreas de Investigación

El Área de Robótica del Instituto ai2 desarrolla su actividad en el estudio, análisis y desarrollo de investigación básica y aplicada para cubrir los aspectos de control, sensorización, programación y planificación de los sistemas robotizados en sus diferentes plataformas (brazos articulados, robots móviles y robots humanoides).

Grupo de Robótica

Contacto

Carlos Ricolfe

El Área de Robótica del Instituto ai2 desarrolla su actividad en el estudio, análisis y desarrollo de investigación básica y aplicada para cubrir los aspectos de control, sensorización, programación y planificación de los sistemas robotizados en sus diferentes plataformas (brazos articulados, robots móviles y robots humanoides).

Grupo de Robótica

Contacto

Carlos Ricolfe

Líneas de Investigación

Asesoramiento en implantación de la robótica

Manipulación de productos delicados

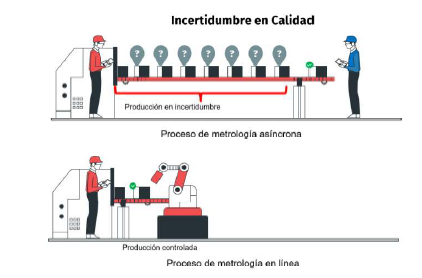
Pick-Inspection-Place

Plataformas para rehabilitación

Robótica móvil

Proyectos

Publicaciones

  • Capítulo de Libro: 2025, Advanced Technologies and the University of the Future,
    Referencia: Actuators in Robotic Control – 2nd Edition, Capítulo:  10, Páginas: 178- 194
    Editorial: Multidisciplinary Digital Publishing Institute (MDPI) – 9783725829903,
    Autores: Vendrell Vidal, Eduardo; Uriel Ruben Cukierman,; Michael E. Auer
  • Libro: 2025, Advanced Technologies and the University of the Future,
    Páginas: 510
    Editorial: Springer- 978-3-031-71529-7,
    Autores: Vendrell Vidal, Eduardo; Uriel Ruben Cukierman,; Michael E. Auer
  • Libro: 2025, Manipuladores paralelos: Síntesis, análisis y aplicaciones,
    Páginas: 245
    Editorial: Universidad Tecnológica de Pereira (Colombia) – 978-958-722-317-0,
    Autores: Hector F. Quintero; MEJIA CALDERON, LUZ ADRIANA; German A. Holguin; Díaz-Rodríguez, Miguel Ángel; Herrera-López, Enrique; CAM; GDP2
  • Tesis: 2024, Design and Implementation of Model-Based and Learning Control for Rehabilitation Parallel Robots: Advancements and Performance Evaluation
    Fecha de publicación: 19/12/2024
    Autor: Rafael José Escarabajal Sánchez,
    Director/es: Valera Fernández, Ángel; Vallés Miquel, Marina
  • Artículo: 2024, Fast Coincidence Filter for Silicon Photomultiplier Dark Count Rate Rejection,
    Revista: Sensors, Numero , Volumen 24, Páginas: –
    DOI: https://doi.org/10.3390/s24072084 – HANDLE: http://hdl.handle.net/10251/206882
    Autores: Real, Diego; Calvo, David; Zornoza, Juan de Dios; Manzaneda, Mario; Gozzini, Rebecca; Ricolfe Viala, Carlos; Lajara, Rafael; Albiol, Francisco
  • Artículo: 2024, Operation of DR-HVdc-Connected Grid-Forming Wind Turbine Converters Using Robust Loop-Shaping Controllers,
    Revista: Applied Sciences, Numero , Volumen 14, Páginas: –
    DOI: https://doi.org/10.3390/app14020881 – HANDLE: http://hdl.handle.net/10251/203558
    Autores: Martínez-Turégano, Jaime; Sala, Antonio; Blasco-Gimenez, Ramon; Blanes Campos, Carlos
  • Capítulo de Libro: 2024, Robótica e Internet de las Cosas en la Administración,
    Referencia: La administración digital en la era de las tecnologías disruptivas. Transformando la gestión pública, Capítulo:  9, Páginas: 228- 250
    Editorial: La Ley – 978-84-7052-957-3,
    Autores:
  • Libro: 2024, Towards a Hybrid, Flexible and Socially Engaged Higher Education. Proceedings of the 26th International Conference on Interactive Collaborative Learning (ICL2023), Volume 1,
    Páginas: 553
    Editorial: Springer – 978-3-031-51978-9,
    Autores: Michael E. Auer; Uriel R. Cukierman,; Vendrell Vidal, Eduardo; EDMUNDO TOVAR CARO
  • Libro: 2024, Towards a Hybrid, Flexible and Socially Engaged Higher Education. Proceedings of the 26th International Conference on Interactive Collaborative Learning (ICL2023), Volume 2,
    Páginas: 502
    Editorial: Springer – 978-3-031-52666-4,
    Autores: Michael E. Auer; Uriel R. Cukierman,; Vendrell Vidal, Eduardo; Edmundo Tovar Caro
  • Libro: 2024, Towards a Hybrid, Flexible and Socially Engaged Higher Education. Proceedings of the 26th International Conference on Interactive Collaborative Learning (ICL2023), Volume 3,
    Páginas: 517
    Editorial: Springer – 978-3-031-53022-7,
    Autores: Michael E. Auer; Uriel R. Cukierman; Vendrell Vidal, Eduardo; Edmundo Tovar Caro
  • Libro: 2024, Towards a Hybrid, Flexible and Socially Engaged Higher Education. Proceedings of the 26th International Conference on Interactive Collaborative Learning (ICL2023), Volume 4,
    Páginas: 531
    Editorial: Springer – 978-3-031-53381-5,
    Autores: Michael E. Auer; Uriel R. Cukierman; Vendrell Vidal, Eduardo; Edmundo Tovar Caro
  • Tesis: 2023, A new index for detecting and avoiding Type II singularities for the control of non-redundant parallel robots
    Fecha de publicación: 15/05/2023
    Autor: José Luis Pulloquinga Zapata,
    Director/es: Mata Amela, Vicente; Valera Fernández, Ángel
  • Artículo: 2023, A Type II singularity avoidance algorithm for parallel manipulators using output twist screws,
    Revista: Mechanism and Machine Theory, Numero , Volumen 183, Páginas: –
    DOI: https://doi.org/10.1016/j.mechmachtheory.2023.105282 – HANDLE: http://hdl.handle.net/10251/204370
    Autores: Pulloquinga-Zapata, José; Escarabajal-Sánchez, Rafael José; Valera Fernández, Ángel; Vallés Miquel, Marina; Mata Amela, Vicente
  • Artículo: 2023, Admittance controller complemented with real-time singularity avoidance for rehabilitation parallel robots,
    Revista: Mechatronics, Numero , Volumen 94, Páginas: –
    DOI: https://doi.org/10.1016/j.mechatronics.2023.103017 – HANDLE: http://hdl.handle.net/10251/200862
    Autores: Pulloquinga-Zapata, José Luis; Escarabajal-Sánchez, Rafael José; Vallés Miquel, Marina; Díaz-Rodríguez, Miguel; Mata Amela, Vicente; Valera Fernández, Ángel
  • Artículo: 2023, Analysis of a C. elegans lifespan prediction method based on a bimodal neural network and uncertainty estimation,
    Revista: Computational and Structural Biotechnology Journal, Numero , Volumen 21, Páginas: –
    DOI: https://doi.org/10.1016/j.csbj.2022.12.033 – HANDLE: http://hdl.handle.net/10251/200925
    Autores: García-Garví, Antonio; Layana-Castro, Pablo Emmanuel; Sánchez Salmerón, Antonio José
  • Artículo: 2023, Automatic segmentation of Caenorhabditis elegans skeletons in worm aggregations using improved U-Net in low-resolution image sequences,
    Revista: Heliyon, Numero , Volumen 9, Páginas: –
    DOI: https://doi.org/10.1016/j.heliyon.2023.e14715 – HANDLE: http://hdl.handle.net/10251/200870
    Autores: Layana-Castro, Pablo Emmanuel; García-Garví, Antonio; Sánchez Salmerón, Antonio José
  • Artículo: 2023, Automation of Caenorhabditis elegans lifespan assay using a simplified domain synthetic image-based neural network training strategy,
    Revista: Computational and Structural Biotechnology Journal, Numero , Volumen 21, Páginas: –
    DOI: https://doi.org/10.1016/j.csbj.2023.10.007 – HANDLE: http://hdl.handle.net/10251/200928
    Autores: García-Garví, Antonio; Layana-Castro, Pablo Emmanuel; Puchalt-Rodríguez, Joan Carles; Sánchez Salmerón, Antonio José
  • Artículo: 2023, Combined Admittance Control With Type II Singularity Evasion for Parallel Robots Using Dynamic Movement Primitives,
    Revista: IEEE Transactions on Robotics, Numero , Volumen 39, Páginas: –
    DOI: https://doi.org/10.1109/TRO.2023.3238136 – HANDLE: http://hdl.handle.net/10251/200923
    Autores: Escarabajal-Sánchez, Rafael José; Pulloquinga-Zapata, José; Valera Fernández, Ángel; Mata Amela, Vicente; Vallés Miquel, Marina; Castillo-García, Fernando J.
  • Tesis: 2023, Desarrollo de técnicas avanzadas de seguimiento de posturas para reconocimiento de comportamientos de C. elegans
    Fecha de publicación: 22/09/2023
    Autor: Pablo Emmanuel Layana Castro,
    Director/es: Sánchez Salmerón, Antonio José
  • Artículo: 2023, Hardware-in-the-Loop Test Bench for Simulation of Catenary-Pantograph Interaction (CPI) with Linear Camera Measurement,
    Revista: Sensors, Numero , Volumen 23, Páginas: –
    DOI: https://doi.org/10.3390/s23041773 – HANDLE: http://hdl.handle.net/10251/201340
    Autores: Correcher Salvador, Antonio; Ricolfe Viala, Carlos; Tur Valiente, Manuel; Gregori Verdú, Santiago; Salvador-Muñoz, Mario; Fuenmayor Fernández, Francisco-Javier; Gil-Romero, Jaime; Pedrosa, Ana M.
  • Artículo: 2023, Imitation Learning-Based System for the Execution of Self-Paced Robotic-Assisted Passive Rehabilitation Exercises,
    Revista: IEEE Robotics and Automation Letters, Numero , Volumen 8, Páginas: –
    DOI: https://doi.org/10.1109/LRA.2023.3281884 – HANDLE: http://hdl.handle.net/10251/201738
    Autores: Escarabajal-Sánchez, Rafael José; Pulloquinga-Zapata, José; Zamora-Ortiz, Pau; Valera Fernández, Ángel; Mata Amela, Vicente; Vallés Miquel, Marina
  • Artículo: 2023, Model-Based Control of a 4-DOF Rehabilitation Parallel Robot with Online Identification of the Gravitational Term,
    Revista: Sensors, Numero , Volumen 23, Páginas: –
    DOI: https://doi.org/10.3390/s23052790 – HANDLE: http://hdl.handle.net/10251/202749
    Autores: Escarabajal-Sánchez, Rafael José; Pulloquinga-Zapata, José Luis; Mata Amela, Vicente; Valera Fernández, Ángel; Díaz-Rodríguez, Miguel
  • Artículo: 2023, Skeletonizing Caenorhabditis elegans Based on U-Net Architectures Trained with a Multi-worm Low-Resolution Synthetic Dataset,
    Revista: International Journal of Computer Vision, Numero , Volumen 131, Páginas: –
    DOI: https://doi.org/10.1007/s11263-023-01818-6 – HANDLE: http://hdl.handle.net/10251/200935
    Autores: Layana-Castro, Pablo Emmanuel; García-Garví, Antonio; Navarro Moya, Francisco; Sánchez Salmerón, Antonio José
  • Artículo: 2023, Towards generalization for Caenorhabditis elegans detection,
    Revista: Computational and Structural Biotechnology Journal, Numero , Volumen 21, Páginas: –
    DOI: https://doi.org/10.1016/j.csbj.2023.09.039 – HANDLE: http://hdl.handle.net/10251/202339
    Autores: Escobar-Benavides, Santiago; García-Garví, Antonio; Layana-Castro, Pablo Emmanuel; Sánchez Salmerón, Antonio José
  • Artículo: 2022, A Computationally Efficient Musculoskeletal Model of the Lower Limb for the Control of Rehabilitation Robots: Assumptions and Validation,
    Revista: Applied Sciences, Numero 5, Volumen 12, Páginas: 2654- 2670
    DOI: https://doi.org/10.3390/app12052654 – HANDLE:
    Autores: Farhat, Nidal; Zamora-Ortiz, Pau; David Reichert; Mata Amela, Vicente; Page Del Pozo, Alvaro Felipe; Valera Fernández, Ángel
  • Artículo: 2022, A new training strategy for spatial transform networks (STN’s),
    Revista: Neural Computing and Applications, Numero , Volumen , Páginas: 10081- 10092
    DOI: https://doi.org/10.1007/s00521-022-06993-0 – HANDLE:
    Autores: Francisco Navarro Moya; Puchalt-Rodríguez, Joan Carles; Layana-Castro, Pablo Emmanuel; García-Garví, Antonio; Sánchez Salmerón, Antonio José
  • Tesis: 2022, Development and evaluation of new methods for automating experiments with C. elegans based on active vision
    Fecha de publicación: 03/02/2022
    Autor: Joan Carles Puchalt Rodríguez,
    Director/es: Sánchez Salmerón, Antonio José
  • Artículo: 2022, Gravitational Base Parameters Identification for a Knee Rehabilitation Parallel Robot,
    Revista: International Journal on Advanced Science, Engineering and Information Technology, Numero 2, Volumen 12, Páginas: 501- 507
    DOI: https://doi.org/10.18517/ijaseit.12.2.15289 – HANDLE:
    Autores: Pulloquinga-Zapata, José; Escarabajal-Sánchez, Rafael José; Mata Amela, Vicente; Valera Fernández, Ángel; Ivan Zambrano; Andrés Rosales
  • Artículo: 2022, Identifying the Inertial Properties of a Padel Racket: An Experimental Maneuverability Proposal,
    Revista: Sensors, Numero , Volumen 22, Páginas: 1- 22
    DOI: https://doi.org/10.3390/s22239266 – HANDLE:
    Autores: Blanes Campos, Carlos; Correcher Salvador, Antonio; Beltrán Beltrán, Pablo; Mellado, Martin
  • Artículo: 2022, Improving Robot Perception Skills Using a Fast Image-Labelling Method with Minimal Human Intervention,
    Revista: Applied Sciences, Numero 3, Volumen 12, Páginas: –
    DOI: https://doi.org/10.3390/app12031557 – HANDLE:
    Autores: Ricolfe Viala, Carlos; Blanes Campos, Carlos
  • Artículo: 2022, Multiview motion tracking based on a cartesian robot to monitor Caenorhabditis elegans in standard Petri dishes,
    Revista: Scientific Reports, Numero 1, Volumen 12, Páginas: 1- 11
    DOI: https://doi.org/10.1038/s41598-022-05823-6 – HANDLE:
    Autores: Puchalt-Rodríguez, Joan Carles; González-Rojo, José Félix; Gómez-Escribano, Ana Pilar; R.P. Vázquez-Manrique; Sánchez Salmerón, Antonio José
  • Artículo: 2022, Predictive Fault Diagnosis for Ship Photovoltaic Modules Systems Applications,
    Revista: Sensors, Numero 6, Volumen 22, Páginas: 1- 21
    DOI: https://doi.org/10.3390/s22062175 – HANDLE:
    Autores: García Moreno, Emilio; Quiles Cucarella, Eduardo; Zotovic Stanisic, Ranko; Gutiérrez, S. C.
  • Tesis: 2022, Propuesta de inclusión de esfuerzos en el control de un brazo robot para asegurar el cumplimiento de la rugosidad superficial durante operaciones de lijado en diferentes materiales
    Fecha de publicación: 04/03/2022
    Autor: Rodrigo Alonso Pérez Ubeda,
    Director/es: Gutiérrez, S. C.; Zotovic Stanisic, Ranko
  • Artículo: 2022, Solar Panels String Predictive and Parametric Fault Diagnosis Using Low-Cost Sensors,
    Revista: Sensors, Numero 1, Volumen 22, Páginas: 1- 29
    DOI: https://doi.org/10.3390/s22010332 – HANDLE:
    Autores: García Moreno, Emilio; Neisser Ponluisa; Quiles Cucarella, Eduardo; Zotovic Stanisic, Ranko; Gutiérrez, S. C.
  • Tesis: 2022, Synthesis of the Complete Inverse Kinematic Model of Non-Redundant Open-Chain Robotic Systems using Groebner Basis Theory
    Fecha de publicación: 28/01/2022
    Autor: José Guzmán Giménez,
    Director/es: Valera Fernández, Ángel
  • Artículo: 2022, Turmell-Meter: A Device for Estimating the Subtalar and Talocrural Axes of the Human Ankle Joint by Applying the Product of Exponentials Formula,
    Revista: Bioengineering, Numero , Volumen 9, Páginas: 199-1- 199-35
    DOI: https://doi.org/10.3390/bioengineering9050199 – HANDLE:
    Autores: O. Agudelo-Varela; Vargas-Riaño, Julio Hernando; Valera Fernández, Ángel
  • Artículo: 2021, A Database for Learning Numbers by Visual Finger Recognition in Developmental Neuro-Robotics,
    Revista: Frontiers in Neurorobotics, Numero , Volumen , Páginas: –
    DOI: https://doi.org/10.3389/fnbot.2021.619504 – HANDLE:
    Autores: Sergio Davies; Alexandr Lucas; Ricolfe Viala, Carlos; Alessandro Di Nuovo
  • Artículo: 2021, The Influence of Autofocus Lenses in the Camera Calibration Process,
    Revista: IEEE Transactions on Instrumentation and Measurement, Numero , Volumen 70, Páginas: 1- 15
    DOI: https://doi.org/10.1109/TIM.2021.3055793 – HANDLE:
    Autores: Ricolfe Viala, Carlos; Esparza Peidro, Alicia
  • Artículo: 2021, Towards Lifespan Automation for Caenorhabditis elegans Based on Deep Learning: Analysing Convolutional and Recurrent Neural Networks for Dead or Live Classification,
    Revista: Sensors, Numero 14, Volumen 21, Páginas: 4943- 4950
    DOI: https://doi.org/10.3390/s21144943 – HANDLE:
    Autores: García-Garví, Antonio; Puchalt-Rodríguez, Joan Carles; Layana-Castro, Pablo Emmanuel; Francisco Navarro Moya; Sánchez Salmerón, Antonio José
  • Artículo: 2021, Vision-Based Hybrid Controller to Release a 4-DOF Parallel Robot from a Type II Singularity,
    Revista: Sensors, Numero , Volumen 21, Páginas: 4080-
    DOI: https://doi.org/10.3390/s21124080 – HANDLE:
    Autores: Pulloquinga-Zapata, José; Escarabajal-Sánchez, Rafael José; Jesús Ferrándiz; Vallés Miquel, Marina; Mata Amela, Vicente; Mónica Urízar
  • Artículo: 2021, Automatic selection of the Groebner Basis monomial order employed for the synthesis of the inverse kinematic model of non-redundant open-chain robotic systems,
    Revista: Mechanics Based Design of Structures and Machines, Numero , Volumen , Páginas: 1- 22
    DOI: https://doi.org/10.1080/15397734.2021.1899829 – HANDLE:
    Autores: Guzmán Giménez, José; Valera Fernández, Ángel; Mata Amela, Vicente; MIGUEL ÁNGEL DÍAZ RODRÍGUEZ
  • Artículo: 2021, Behavioural Study of the Force Control Loop Used in a Collaborative Robot for Sanding Materials,
    Revista: Materials, Numero 1, Volumen 14, Páginas: 1- 19
    DOI: https://doi.org/10.3390/ma14010067 – HANDLE:
    Autores: Pérez-Ubeda, Rodrigo Alonso; Gutiérrez, S. C.; Zotovic Stanisic, Ranko; Perles Ivars, Angel
  • Artículo: 2021, Caenorhabditis elegans Multi-Tracker Based on a Modified Skeleton Algorithm,
    Revista: Sensors, Numero 16, Volumen 21, Páginas: 5622- 5643
    DOI: https://doi.org/10.3390/s21165622 – HANDLE:
    Autores: Layana-Castro, Pablo Emmanuel; Puchalt-Rodríguez, Joan Carles; García-Garví, Antonio; Sánchez Salmerón, Antonio José
  • Artículo: 2021, Characterization of 3d printing filaments applied in restoration of sensitive archaeological objects using rapid prototyping,
    Revista: Rapid Prototyping Journal, Numero 4, Volumen 27, Páginas: 645- 657
    DOI: https://doi.org/10.1108/RPJ-06-2019-0153 – HANDLE:
    Autores: Aura-Castro, Elvira; Díaz-Marín, María Del Carmen; Mas-Barberà, Xavier; Sánchez López, Miguel; Vendrell Vidal, Eduardo
  • Artículo: 2021, Experimental analysis of Type II singularities and assembly change points in a 3UPS+RPU parallel robot,
    Revista: Mechanism and Machine Theory, Numero , Volumen 158, Páginas: 104242-
    DOI: https://doi.org/10.1016/j.mechmachtheory.2020.104242 – HANDLE:
    Autores: Pulloquinga-Zapata, José; Mata Amela, Vicente; Valera Fernández, Ángel; Zamora-Ortiz, Pau; Díaz-Rodríguez, Miguel; Ivan Zambrano
  • Artículo: 2021, Identification of Inertial Parameters for Position and Force Control of Surgical Assistance Robots,
    Revista: Mathematics, Numero , Volumen 9, Páginas: 773-
    DOI: https://doi.org/10.3390/math9070773 – HANDLE:
    Autores: Zamora-Ortiz, Pau; Javier Carral-Alvaro; Valera Fernández, Ángel; Pulloquinga-Zapata, José; Escarabajal-Sánchez, Rafael José; Mata Amela, Vicente
  • Artículo: 2021, Navigation of Autonomous Light Vehicles Using an Optimal Trajectory Planning Algorithm,
    Revista: Sustainability, Numero 1233, Volumen 13, Páginas: 1- 23
    DOI: https://doi.org/10.3390/su13031233 – HANDLE:
    Autores: Valera Fernández, Ángel; Valero Chuliá, Francisco José; Vallés Miquel, Marina; Besa Gonzálvez, Antonio José; Mata Amela, Vicente; Llopis-Albert, Carlos
  • Artículo: 2021, Small flexible automated system for monitoring Caenorhabditis elegans lifespan based on active vision and image processing techniques,
    Revista: Scientific Reports, Numero 12289, Volumen 11, Páginas: –
    DOI: https://doi.org/10.1038/s41598-021-91898-6 – HANDLE:
    Autores: Puchalt-Rodríguez, Joan Carles; Sánchez Salmerón, Antonio José; Ivorra Martínez, Eugenio; Silvia Llopis; Roberto Martínez; Martorell, Patricia
  • Artículo: 2020, Depth-Dependent High Distortion Lens Calibration,
    Revista: Sensors, Numero 13, Volumen 20, Páginas: 1- 12
    DOI: https://doi.org/10.3390/s20133695 – HANDLE:
    Autores: Ricolfe Viala, Carlos; Esparza Peidro, Alicia
  • Artículo: 2020, Optimal Reconfiguration of a Limited Parallel Robot for Forward Singularities Avoidance,
    Revista: Multidisciplinary Journal for Education, Social and Technological Sciences, Numero 1, Volumen 7, Páginas: 113- 127
    DOI: https://doi.org/10.4995/muse.2020.13352 – HANDLE:
    Autores: Llopis Albert, Carlos; Valero Chuliá, Francisco José; Mata Amela, Vicente; Escarabajal-Sánchez, Rafael José; Zamora-Ortiz, Pau; Pulloquinga-Zapata, José
  • Artículo: 2020, Donning/Doffing and Arm Positioning Influence in Upper Limb Adaptive Prostheses Control,
    Revista: Applied Sciences, Numero 8, Volumen 10, Páginas: 1- 19
    DOI: https://doi.org/10.3390/app10082892 – HANDLE:
    Autores: Igual, Carles; Camacho-García, Andrés; Bernabeu Soler, Enrique Jorge; Igual García, Jorge
  • Artículo: 2020, Optimal Reconfiguration of a Parallel Robot for Forward Singularities Avoidance in Rehabilitation Therapies. A Comparison via Different Optimization Methods,
    Revista: Sustainability, Numero 14, Volumen 12, Páginas: 1- 18
    DOI: https://doi.org/10.3390/su12145803 – HANDLE:
    Autores: Llopis-Albert, Carlos; Valero Chuliá, Francisco José; Mata Amela, Vicente; Pulloquinga-Zapata, José; Zamora-Ortiz, Pau; Escarabajal-Sánchez, Rafael José
  • Artículo: 2020, Improving skeleton algorithm for helping Caenorhabditis elegans trackers,
    Revista: Scientific Reports, Numero 1, Volumen 10, Páginas: 1- 12
    DOI: https://doi.org/10.1038/s41598-020-79430-8 – HANDLE:
    Autores: Layana-Castro, Pablo Emmanuel; Puchalt-Rodríguez, Joan Carles; Sánchez Salmerón, Antonio José
  • Artículo: 2020, Reconfiguration of a parallel kinematic manipulator with 2T2R motions for avoiding singularities through minimizing actuator forces,
    Revista: Mechatronics, Numero , Volumen 69, Páginas: 1- 13
    DOI: https://doi.org/10.1016/j.mechatronics.2020.102382 – HANDLE:
    Autores: Valero Chuliá, Francisco José; Díaz-Rodríguez, Miguel; Vallés Miquel, Marina; Besa Gonzálvez, Antonio José; Bernabeu Soler, Enrique Jorge; Valera Fernández, Ángel
  • Artículo: 2020, Development of lower-limb rehabilitation exercises using 3-PRS Parallel Robot and Dynamic Movement Primitives,
    Revista: Multidisciplinary Journal for Education, Social and Technological Sciences, Numero 2, Volumen 7, Páginas: 30- 44
    DOI: https://doi.org/10.4995/muse.2020.13907 – HANDLE:
    Autores: Escarabajal-Sánchez, Rafael José; ABU-DAKKA, FARES JAWAD MOHD; Pulloquinga-Zapata, José; Mata Amela, Vicente; Vallés Miquel, Marina; Valera Fernández, Ángel
  • Artículo: 2020, Force Control Improvement in Collaborative Robots through Theory Analysis and Experimental Endorsement,
    Revista: Applied Sciences, Numero 12, Volumen 10, Páginas: 1- 24
    DOI: https://doi.org/10.3390/app10124329 – HANDLE:
    Autores: Pérez-Ubeda, Rodrigo; Zotovic Stanisic, Ranko; Gutiérrez, S. C.
  • Artículo: 2020, Passive Exercise Adaptation for Ankle Rehabilitation Based on Learning Control Framework,
    Revista: Sensors, Numero 21, Volumen 20, Páginas: 1- 23
    DOI: https://doi.org/10.3390/s20216215 – HANDLE:
    Autores: Abu-Dakka, Fares J.; Valera Fernández, Ángel; Escalera, Juan A.; Abderrahim, Mohamed ; Page Del Pozo, Alvaro Felipe; Mata Amela, Vicente
  • Artículo: 2020, Improving lifespan automation for Caenorhabditis elegans by using image processing and a post-processing adaptive data filter,
    Revista: Scientific Reports, Numero 1, Volumen 10, Páginas: 1- 14
    DOI: https://doi.org/10.1038/s41598-020-65619-4 – HANDLE:
    Autores: Puchalt-Rodríguez, Joan Carles; Sánchez Salmerón, Antonio José; Ivorra Martínez, Eugenio; Genovés Martínez, Salvador; Martínez, Roberto; Martorell Guerola, Patricia
  • Artículo: 2020, Reducing Results Variance in Lifespan Machines: An Analysis of the Influence of Vibrotaxis on Wild-Type Caenorhabditis elegans for the Death Criterion,
    Revista: Sensors, Numero 21, Volumen 20, Páginas: 1- 17
    DOI: https://doi.org/10.3390/s20215981 – HANDLE:
    Autores: Puchalt-Rodríguez, Joan Carles; Layana-Castro, Pablo Emmanuel; Sánchez Salmerón, Antonio José
  • Artículo: 2020, Synthesis of the Inverse Kinematic Model of Non-Redundant Open-Chain Robotic Systems Using Groebner Basis Theory,
    Revista: Applied Sciences, Numero 8, Volumen 10, Páginas: 1- 22
    DOI: https://doi.org/10.3390/app10082781 – HANDLE:
    Autores: Guzmán-Giménez, José; Valera Fernández, Ángel; Mata Amela, Vicente; Díaz-Rodríguez, Miguel Ángel
  • Artículo: 2019, Active backlight for automating visual monitoring: An analysis of a lighting control technique for Caenorhabditis elegans cultured on standard Petri plates,
    Revista: PLoS ONE, Numero 4, Volumen 14, Páginas: –
    DOI: https://doi.org/10.1371/journal.pone.0215548 – HANDLE:
    Autores: Puchalt-Rodríguez, Joan Carles; Sánchez Salmerón, Antonio José; Martorell, Patricia; Genovés, Salvador
  • Artículo: 2019, An ultra-low pressure pneumatic jamming impact device to non-destructively assess cherimoya firmness,
    Revista: Biosystems Engineering, Numero , Volumen 180, Páginas: 161- 167
    DOI: https://doi.org/10.1016/j.biosystemseng.2019.02.003 – HANDLE:
    Autores: Ortiz Sánchez, María Coral; Blanes Campos, Carlos; Mellado, Martin
  • Artículo: 2019, Event based distributed kalman filter for limited resource multirobot cooperative localization,
    Revista: Asian Journal of Control, Numero 4, Volumen 21, Páginas: 1531- 1546
    DOI: https://doi.org/10.1002/asjc.2141 – HANDLE:
    Autores: MARÍN PANIAGUA, LEONARDO JOSÉ; Soriano Vigueras, Ángel; Vallés Miquel, Marina; Valera Fernández, Ángel; Albertos Pérez, Pedro
  • Artículo: 2019, LINEAR QUADRATIC REGULATOR (LQR) APPLIED TO ELASTIC JOINTS,
    Revista: SCIENTIFIC PROFESIONAL INFORMATIVE JOURNAL, Numero 30, Volumen 23, Páginas: 27- 34
    DOI: – HANDLE:
    Autores: Zotovic Stanisic, Ranko; Isaac Miguez Valle
  • Artículo: 2019, Multi-step approach for automated scaling of photogrammetric micro-measurements,
    Revista: The International Journal of Advanced Manufacturing Technology, Numero 1-4, Volumen 102, Páginas: 747- 757
    DOI: https://doi.org/10.1007/s00170-018-03258-w – HANDLE:
    Autores: A. Frangione; Sánchez Salmerón, Antonio José; F. Modica; Percoco, Gianluca
  • Artículo: 2019, Study of the application of a collaborative robot for machining tasks,
    Revista: Procedia Manufacturing, Numero , Volumen 41, Páginas: 867- 874
    DOI: https://doi.org/10.1016/j.promfg.2019.10.009 – HANDLE:
    Autores: Pérez-Ubeda, R.; Gutiérrez, S. C.; Zotovic Stanisic, Ranko; Lluch-Cerezo, J.
  • Artículo: 2018, Design and Manufacturing of an Ultra-Low-Cost Custom Torque Sensor for Robotics,
    Revista: Sensors, Numero 6, Volumen 18, Páginas: 1- 18
    DOI: https://doi.org/10.3390/s18061786 – HANDLE:
    Autores: Pérez-Ubeda, Rodrigo Alonso; Gutiérrez, S. C.; Zotovic Stanisic, Ranko; Perles Ivars, Angel
  • Artículo: 2018, SEGMENTACIÓN DE MALLAS 3D DE EDIFICIOS HISTÓRICOS PARA LEVANTAMIENTO ARQUITECTÓNICO,
    Revista: Virtual Archaeology Review, Numero 0, Volumen , Páginas: 66- 76
    DOI: https://doi.org/10.4995/var.2018.5858 – HANDLE:
    Autores: Herráez-Concejo, Borja Javier; Vendrell Vidal, Eduardo